Muyang YanI’m a first-year MS Robotics at CMU, advised by Basti Scherer. I’m interested in learning abstractions for planning, especially in multi-agent and human-robot interaction scenarios. In practice I draw from task-and-motion planning, theory-of-mind, program synthesis, and neurosymbolic AI. Previously, I worked with Yexiang Xue and Zak Kingston at Purdue, and Katia Sycara at CMU. |
|
Research |
|
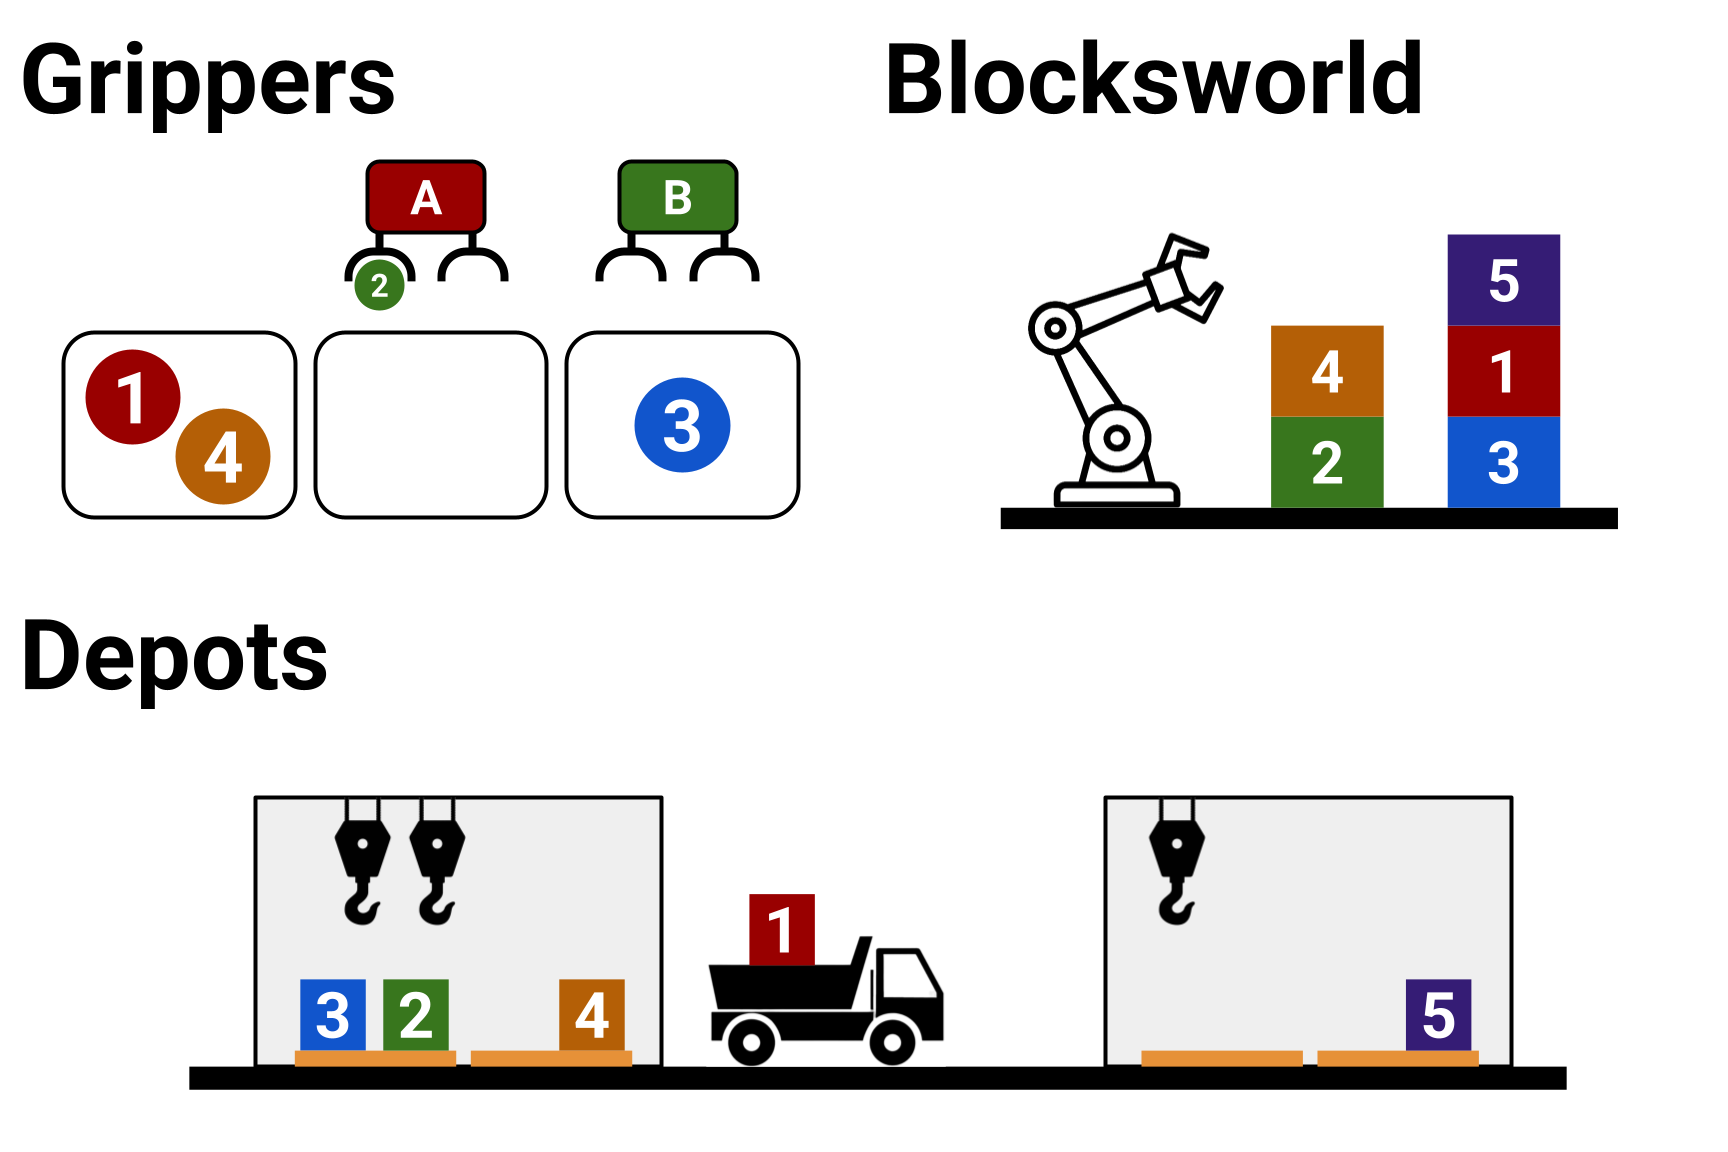
Online Data-Driven Goal Inference with Learned Action SchemasMuyang Yan, Austin Garrett, Maxwell Jacobson, Simon Stepputtis, Katia Sycara, Yexiang Xue, Zachary Kingston IJCAI'26 (Under Review), 2026 Inferring the goals of agents when the underlying domain model is unknown by inferring a posterior over model hypotheses from data. |
|
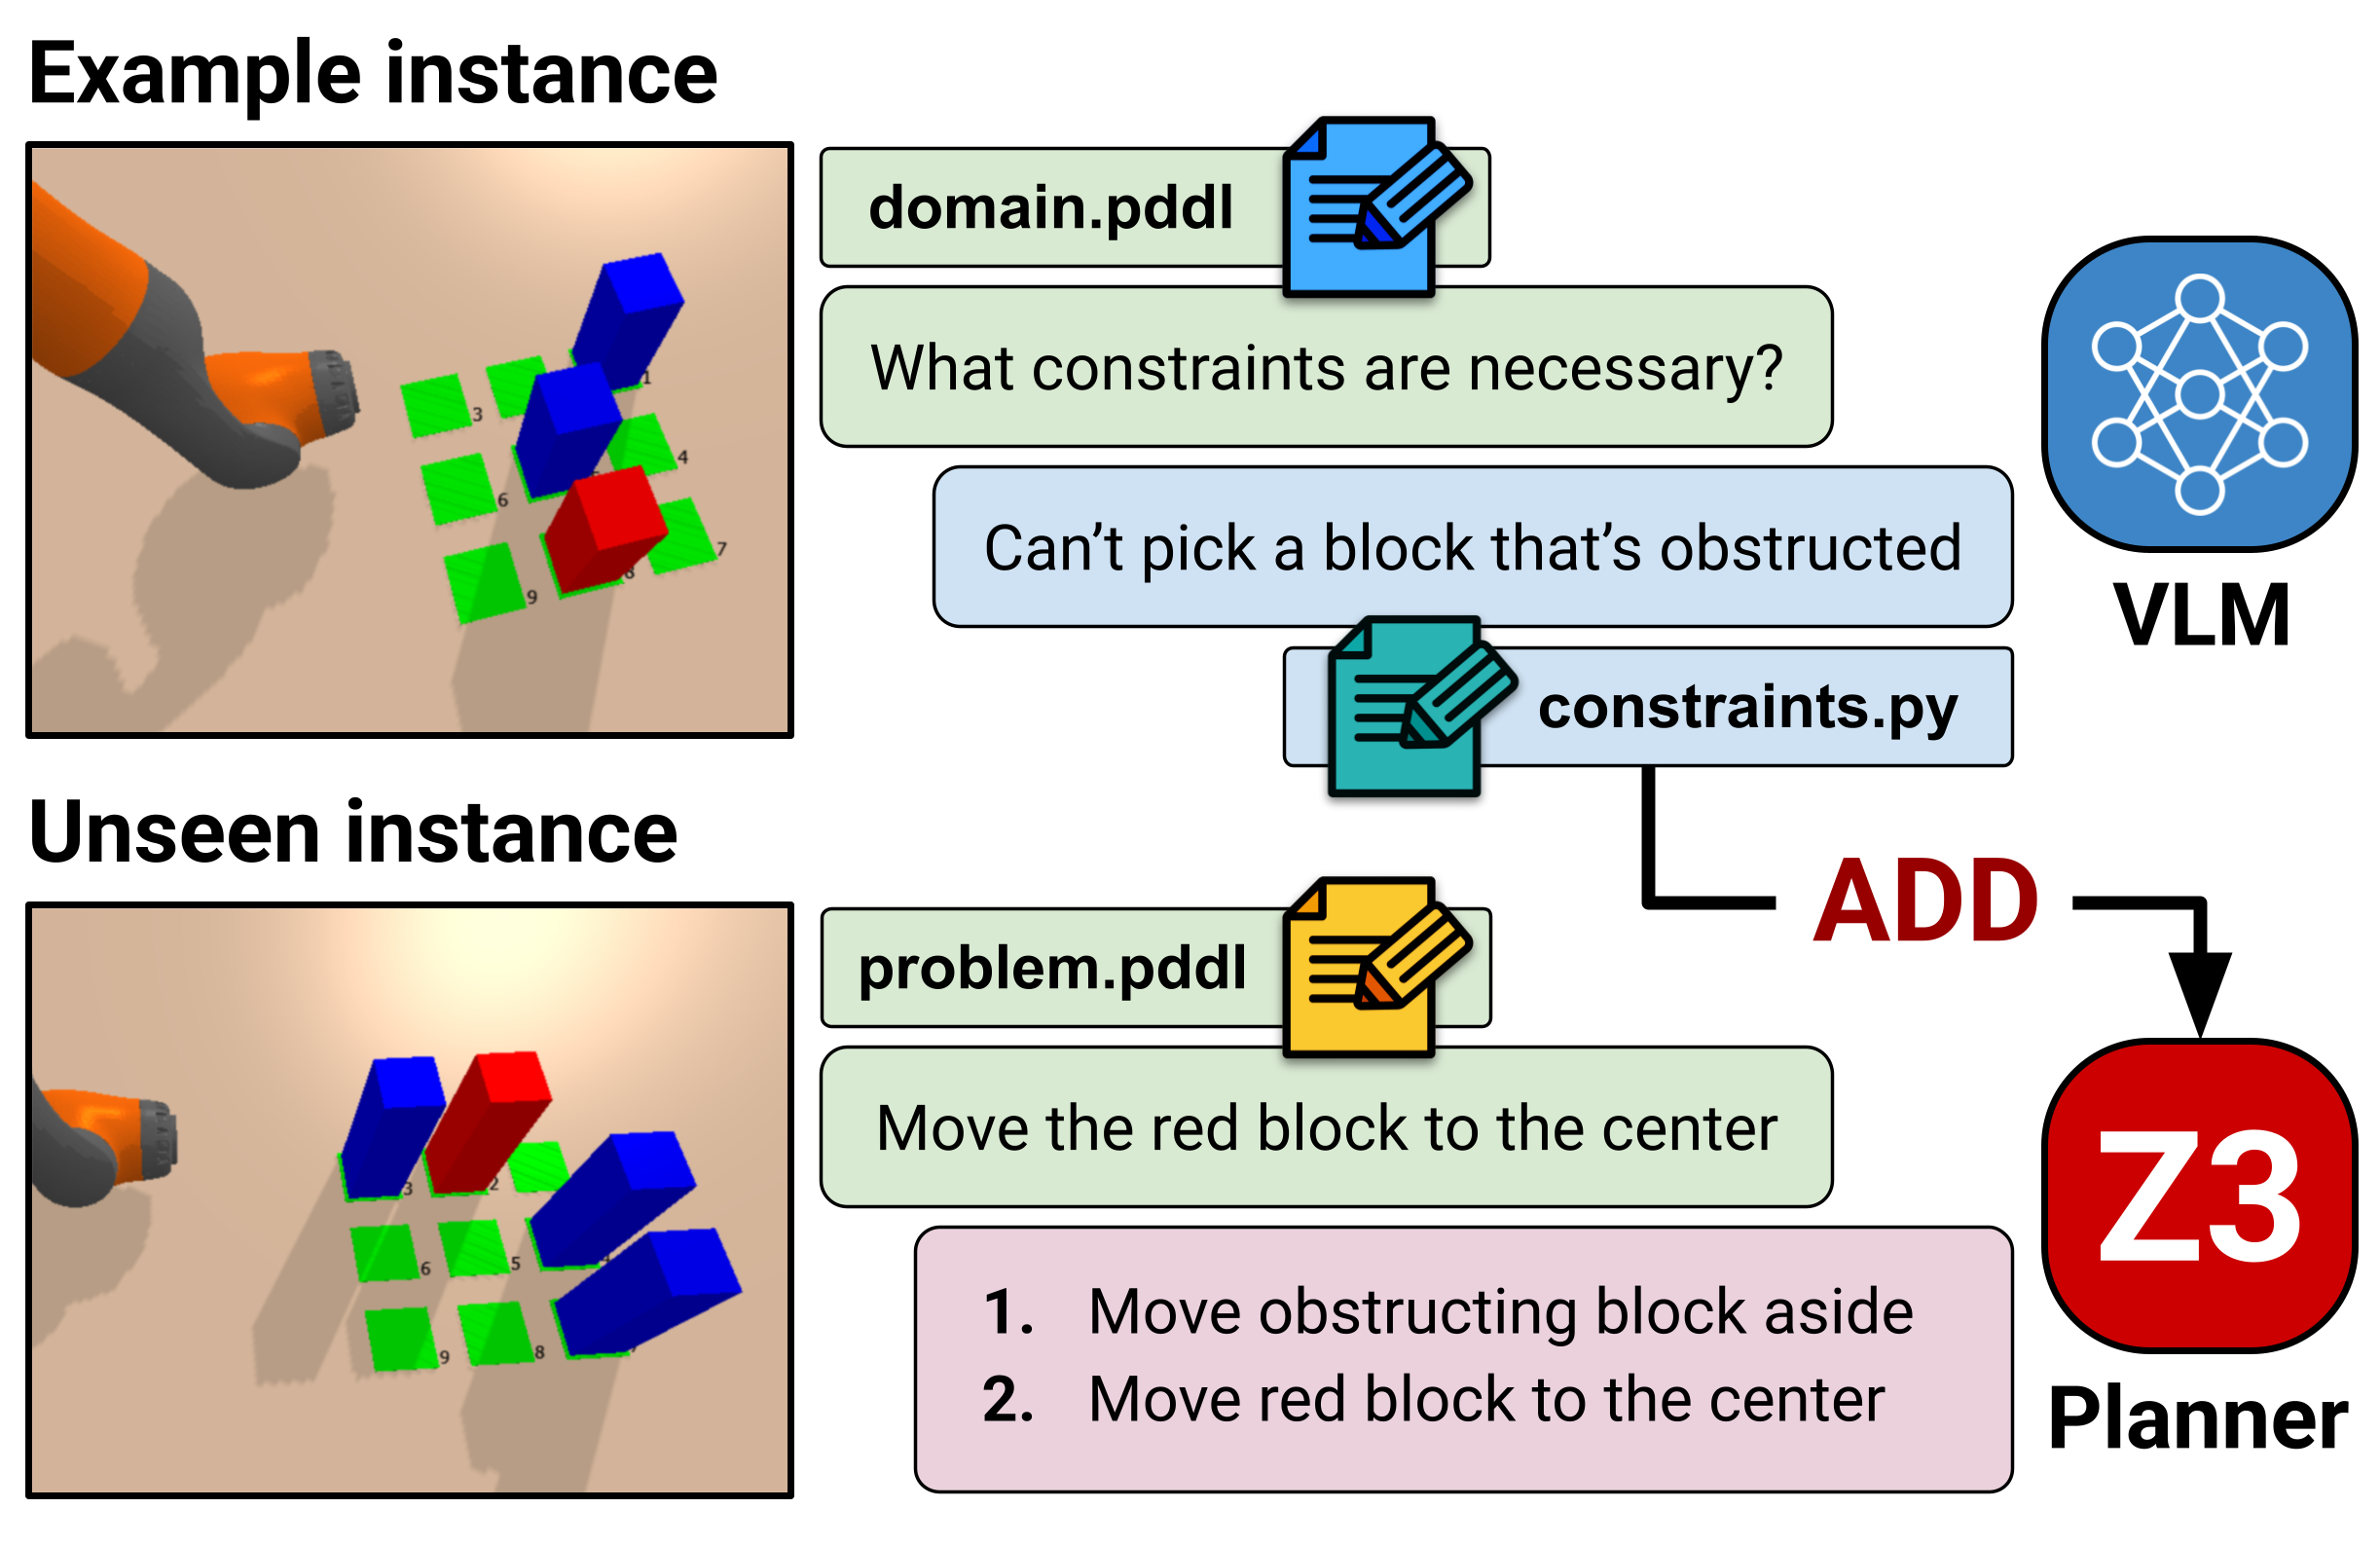
Using VLM Reasoning to Constrain Task and Motion PlanningMuyang Yan, Miras Mengidbayev, Ardon Floros, Weihang Guo, Lydia Kavraki, Zachary Kingston AAAI'27 (Under Review), 2025 Leverage the common-sense spatial reasoning capabilities of VLMs to prevent downward-refinement failures and accelerate planning. |
|
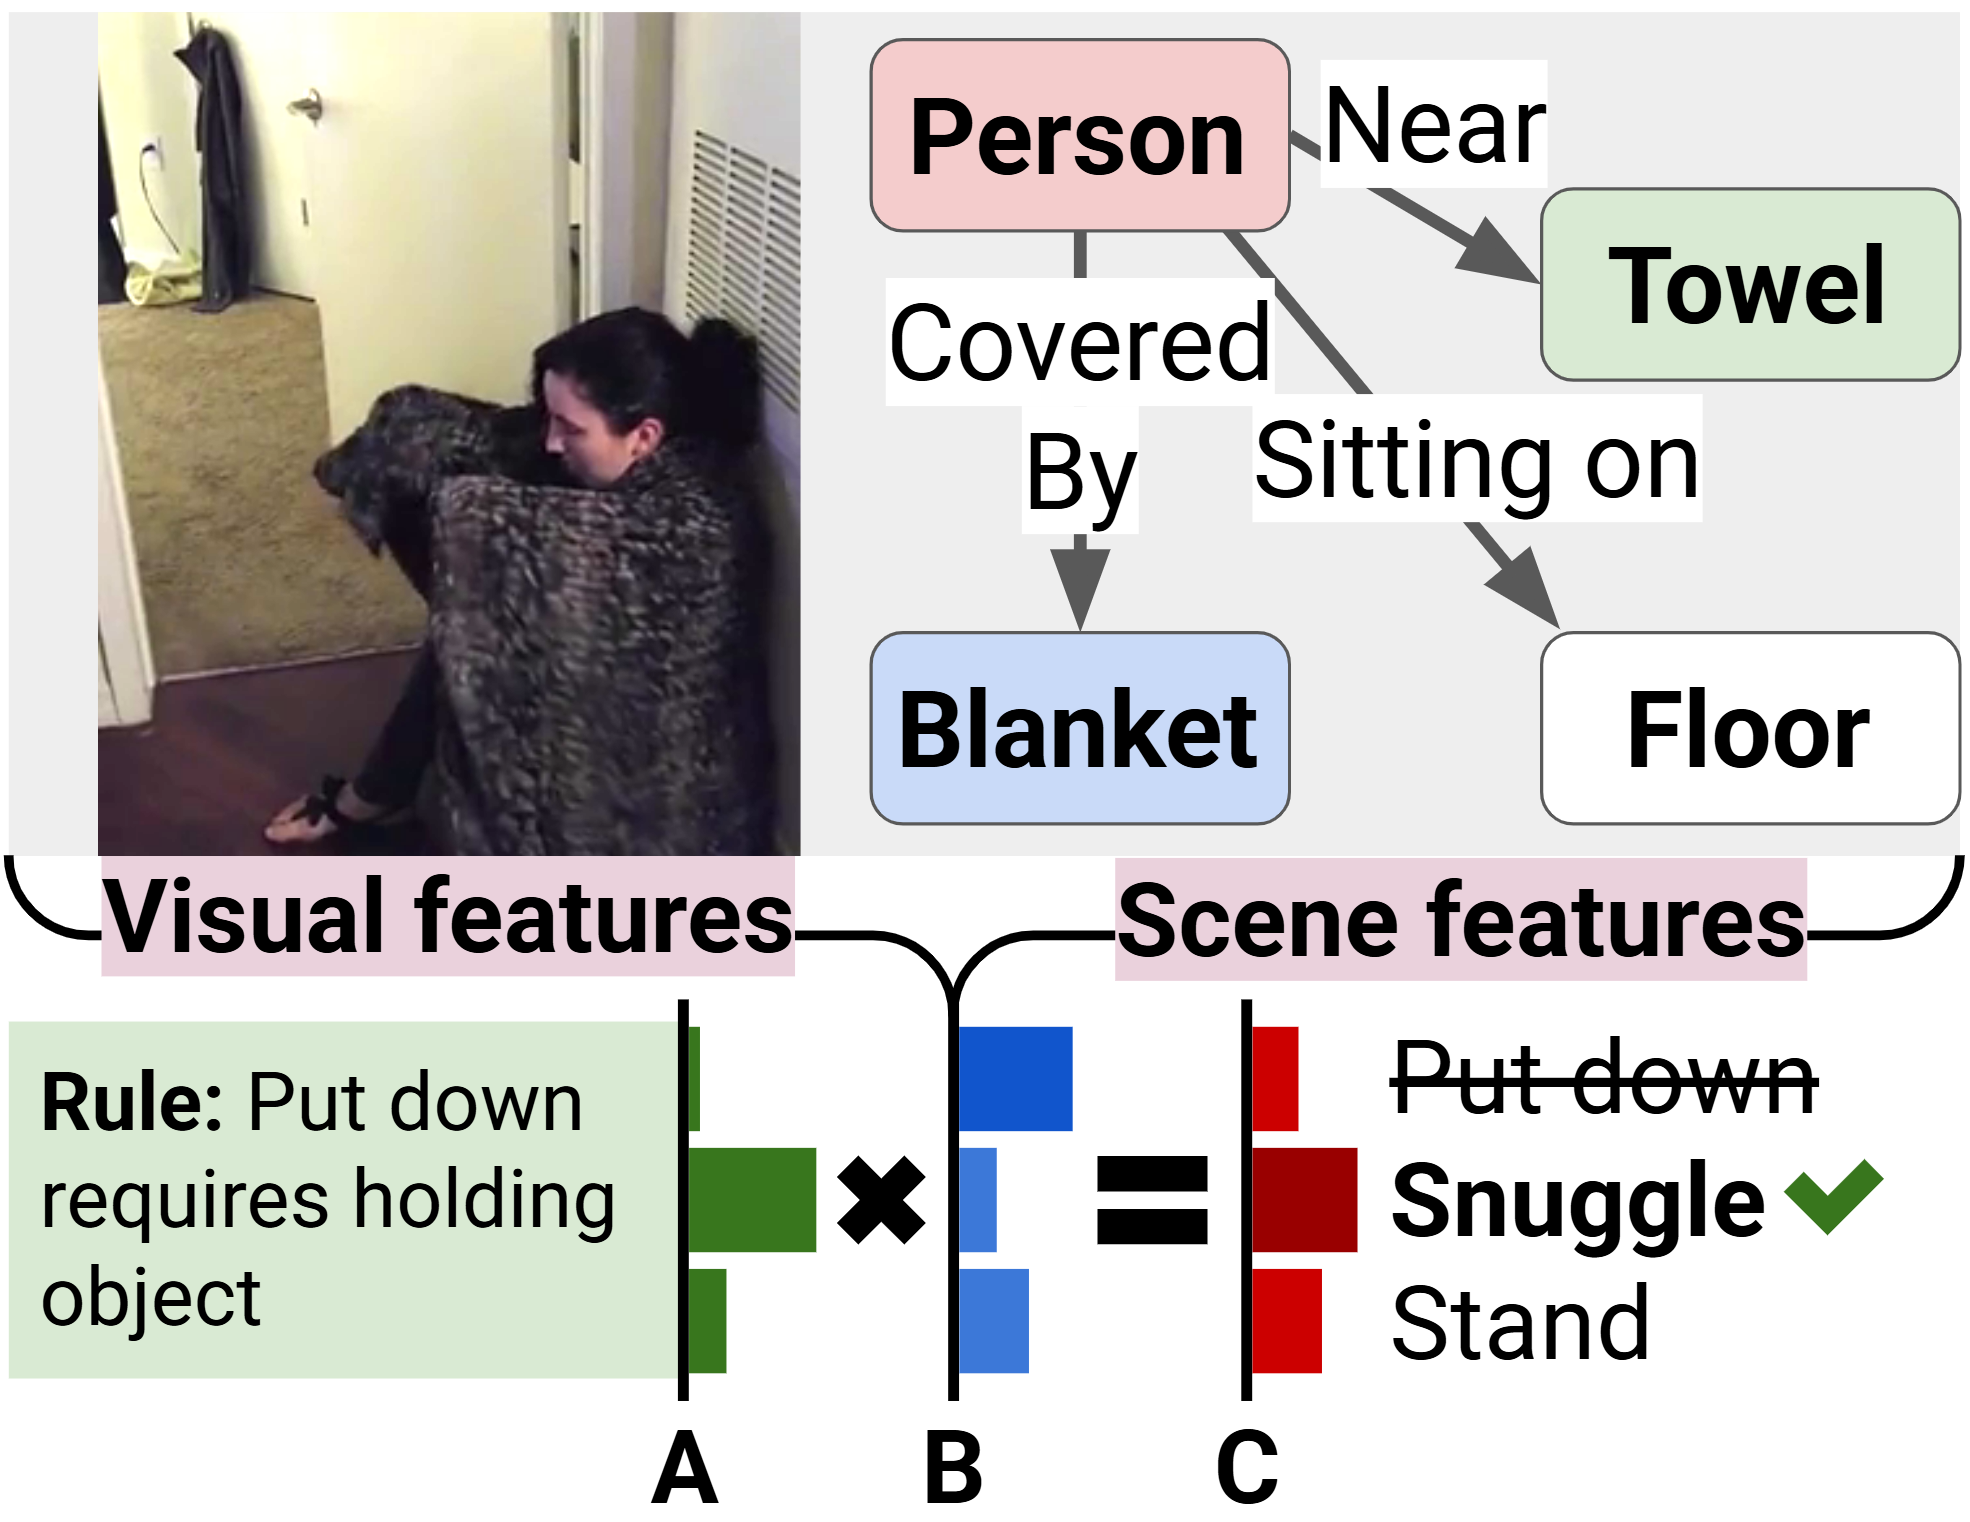
Neuro-Symbolic Action Anticipation from a Single Image with Learned Probabilistic RulesMuyang Yan, Maxwell Jacobson, Nan Jiang, Yaqi Xie, Simon Stepputtis, Katia Sycara, Yexiang Xue AAAI-25 Bridge on Constraint Programming and Machine Learning, 2025 Learning probabilistic action preconditions from data through ILP to anticipate future human actions from single images. |
|
Design and source code from Jon Barron's website |